Conveyor Tracking for Pick and Place: How Robots Hit a Moving Target
How robot conveyor tracking works for pick and place: encoder sync, camera calibration, part latching, prediction, the pick window, and common failures.
October 12, 2026
8 posts
How robot conveyor tracking works for pick and place: encoder sync, camera calibration, part latching, prediction, the pick window, and common failures.
October 12, 2026
What an EtherCAT master does, how software masters compare with hardware ones, and what to check before choosing EtherCAT master software.
October 12, 2026
How we reduced cycle jitter below 1μs using distributed clock synchronization and kernel tuning on standard x86 hardware.
April 15, 2026
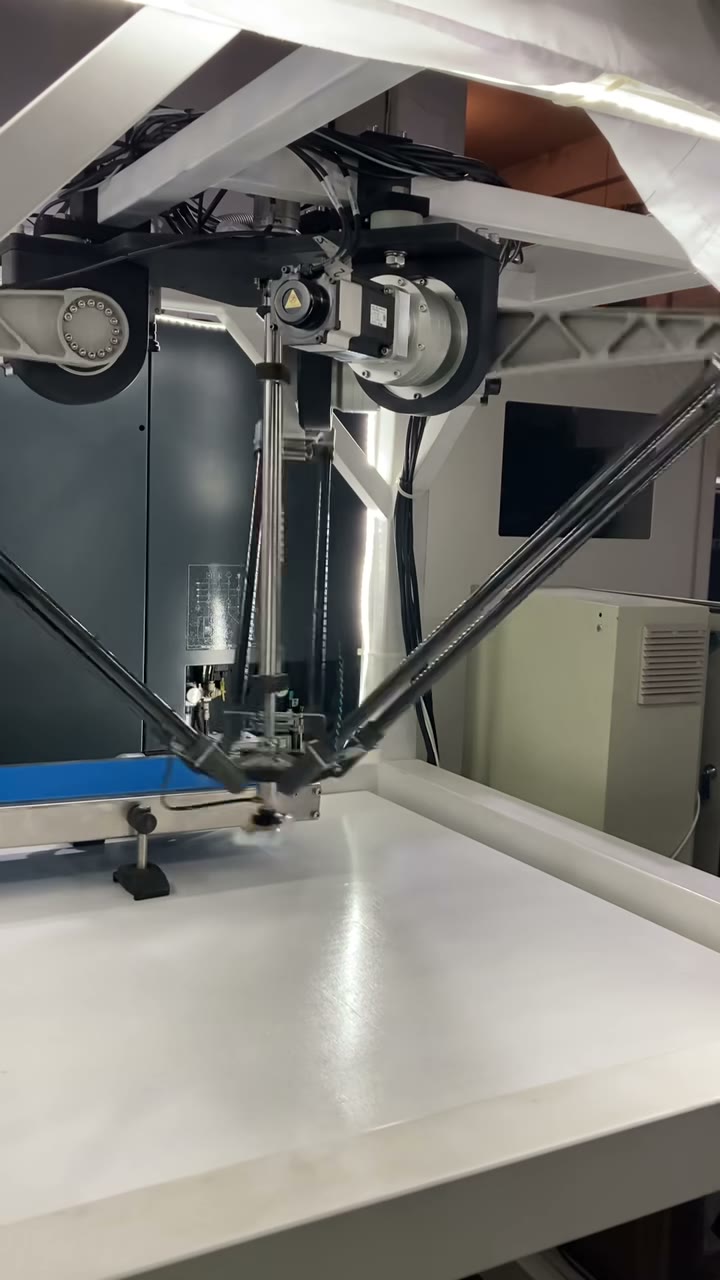
Why we put the Adeeb Delta Robot through mixed-product testing, and the vision, controller and EtherCAT stack that makes it possible.
February 10, 2026
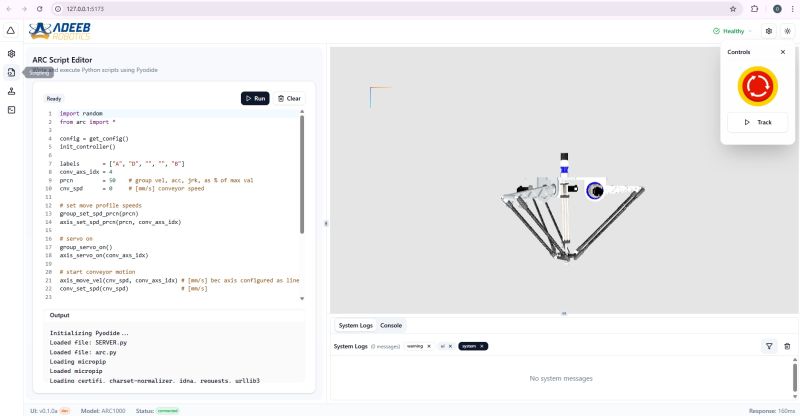
How the Adeeb Robot Controller runs detection, conveyor tracking and stacking from configuration alone, with a UI that mirrors your cell.
January 26, 2026
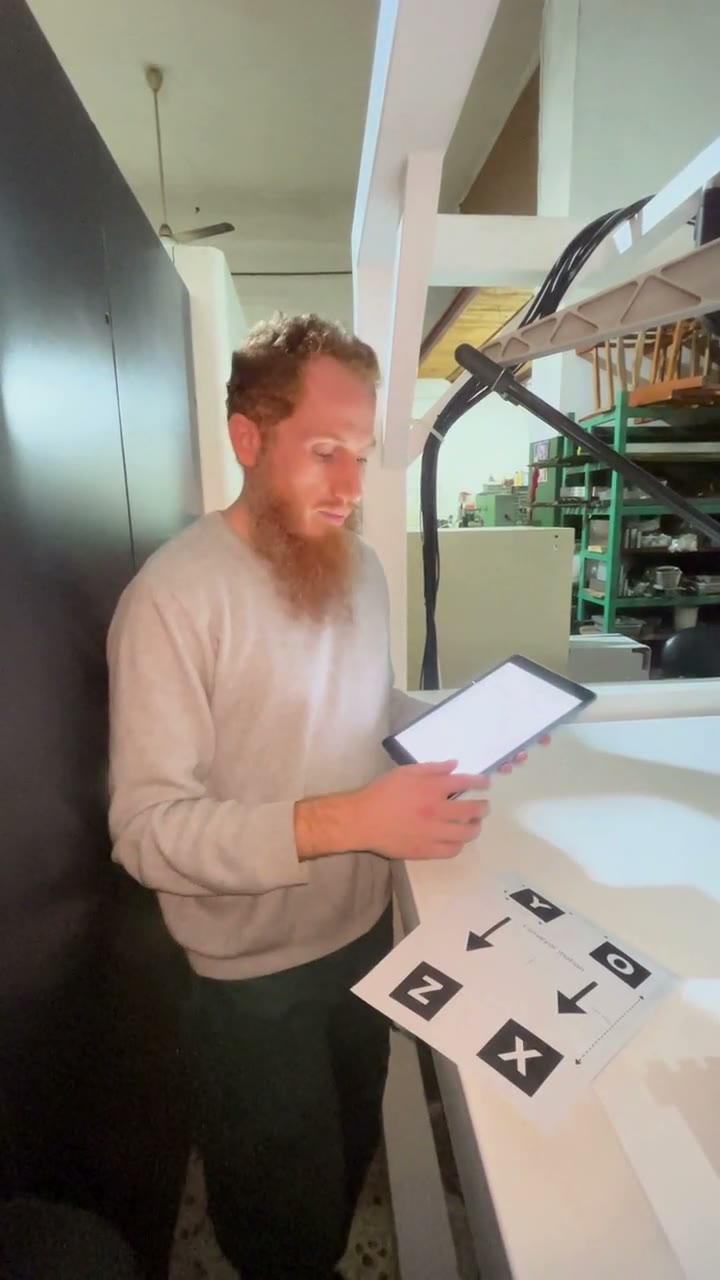
Adeeb's conveyor and camera position calibration commands turn robot cell setup into a two-step process you can run from a tablet in minutes.
January 23, 2026
Why an integrated EtherCAT master, motion stack, and browser UI in a single Rust codebase beats stitching together multi-vendor systems.
January 18, 2026
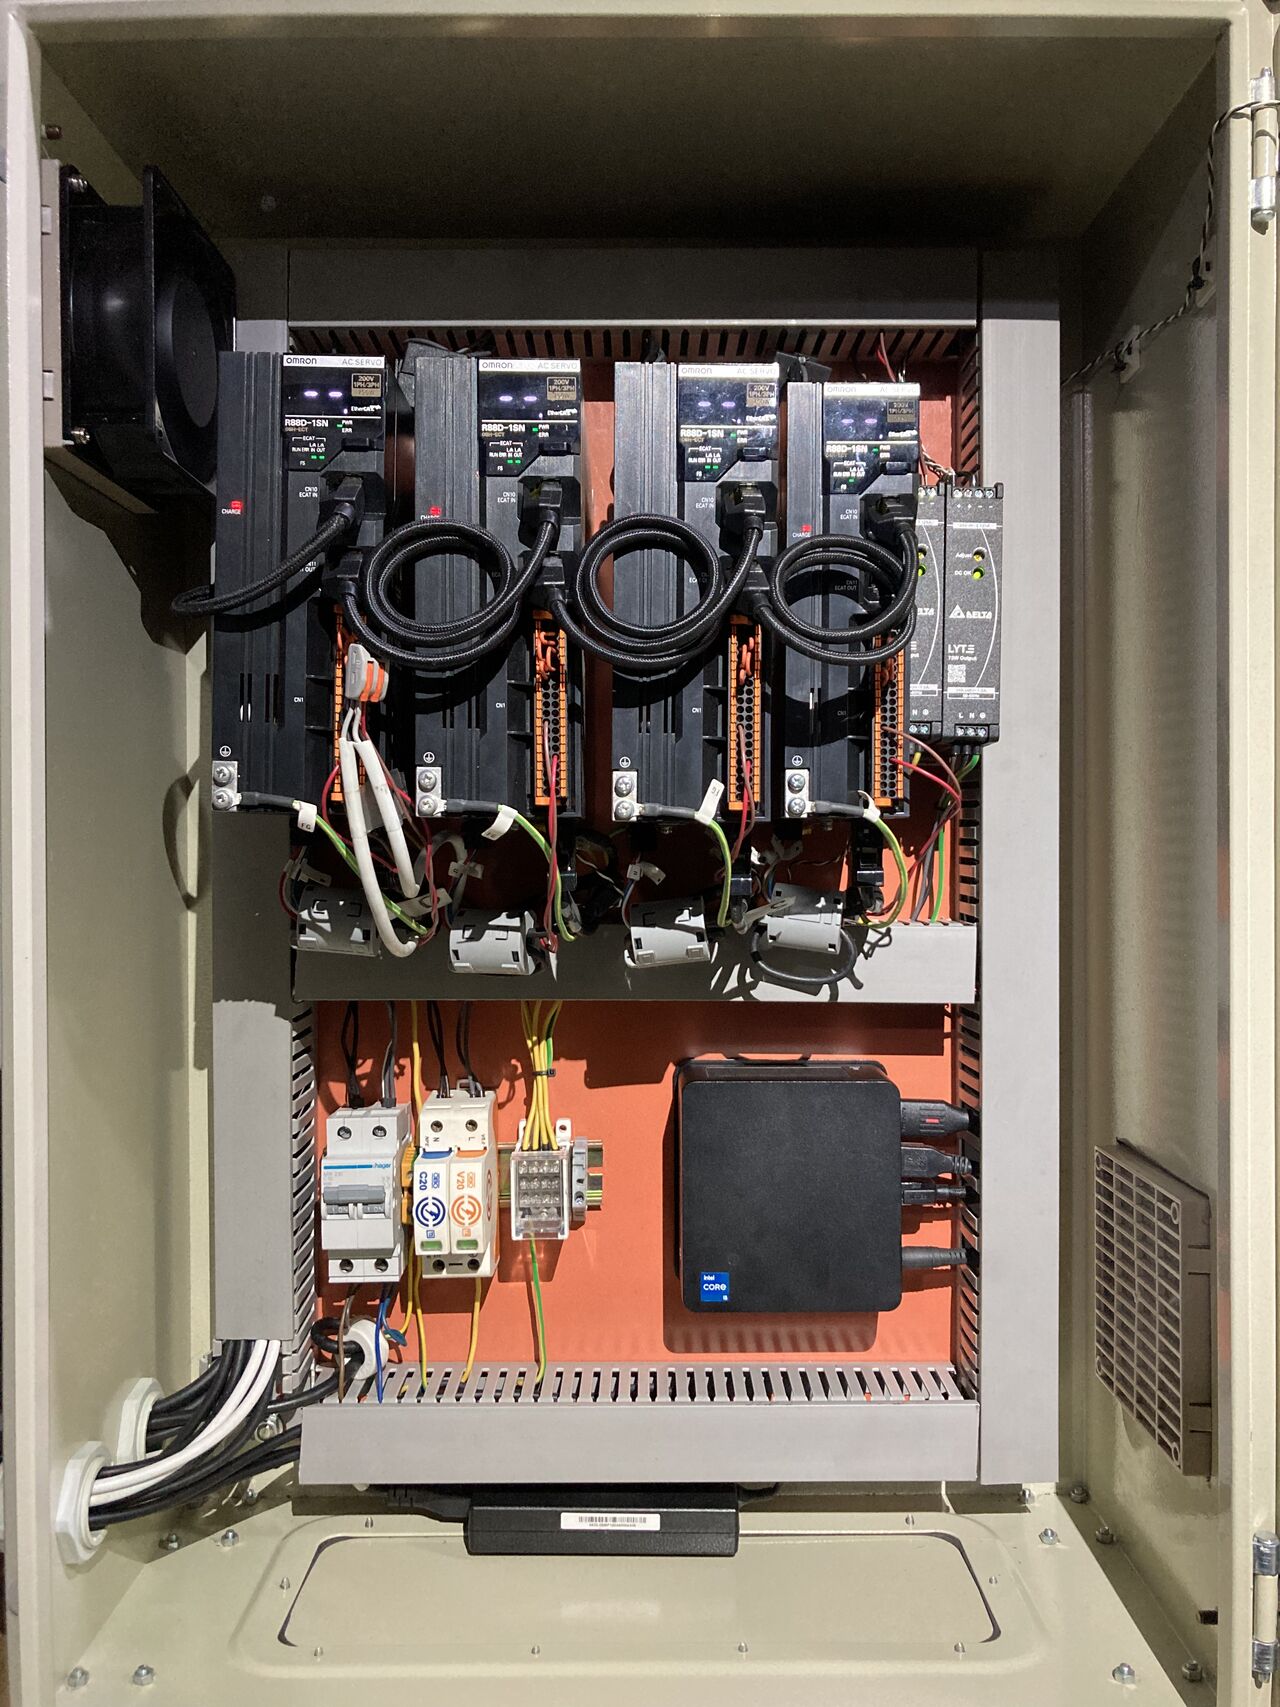
A look inside our Delta robot control panel: four Omron EtherCAT servo drives, an Intel mini PC, and robot kinematics running at 4000 Hz.
January 10, 2026